The relentless pursuit of energy-efficient artificial intelligence has led researchers to look far beyond the traditional confines of silicon-based microchips and power-hungry graphics processing units. In a remarkable fusion of fluid dynamics and computer science, a team at the University of Oxford recently demonstrated that simple water waves can serve as a powerful medium for real-time robotic navigation. This method moves away from the rigid binary logic of modern computers and instead leverages the inherent physical properties of matter to perform complex calculations. By using a framework known as reservoir computing, the scientists found a way to mimic the collective dynamics of the human brain without needing the massive computational overhead typically associated with autonomous systems. This breakthrough addresses one of the most significant challenges in modern robotics: the need for high-performance processing in small, mobile platforms that lack access to vast energy reserves or constant cloud connectivity. The findings, recently published in Nature Communications, mark a pivotal shift toward decentralized intelligence.
Physical Intelligence: The Mechanics of Wave Computing
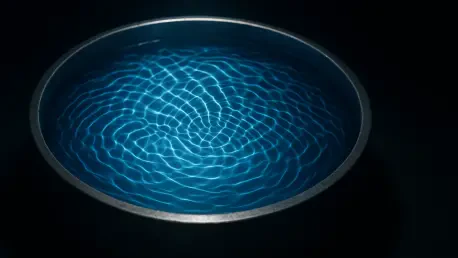
At the heart of this experimental setup is a circular metal container filled with water, which acts as the physical brain of the autonomous vehicle. Environmental data captured by the robot’s sensors is converted into mechanical vibrations that create ripples across the water’s surface. As these waves travel and interact within the vessel, they form intricate interference patterns that represent various obstacle scenarios in the robot’s immediate surroundings. These patterns are not just visual artifacts; they are the result of the water naturally solving complex equations related to spatial awareness and pathfinding. To interpret this physical data, the researchers used LED illumination to visualize the wave peaks and troughs, which were then captured by a camera and translated into movement commands. Unlike traditional artificial intelligence models that require thousands of layers of digital neurons to function, this system achieved perfect accuracy in obstacle recognition by training only the final output stage of the process.
One of the most transformative aspects of this wave-based architecture is its inherent efficiency, particularly through the implementation of an event-driven control mechanism. Conventional autonomous systems usually operate on a constant clock cycle, processing data continuously even when the environment remains static, which leads to significant energy waste and unnecessary heat generation. In contrast, the Oxford system only activates its computational processes when the sensors detect a meaningful change in the surrounding environment, such as a new obstacle or a shift in terrain. This reactive approach drastically reduces latency and minimizes the power consumption required for the robot to make split-second decisions. By allowing the physical dynamics of the water to handle the bulk of the information processing, the system bypasses the bottlenecks often found in standard CPU architectures. This creates a more streamlined and responsive control loop that is ideal for machines operating in unpredictable settings without a data link.
Industrial Transition: Scaling and Commercial Viability
While a container of water might seem impractical for small-scale drones or handheld devices, the underlying physics of this technology are remarkably scalable to the microscopic level. Detailed simulations conducted by the research team, including Professor Thorsten Hesjedal and researchers J. Zohar, D. Pinna, and G. van der Laan, suggested that the same computational principles can be applied using spin waves in magnetic materials. These waves operate at a scale of just one micrometer, which is significantly smaller than the current water-based prototype. This discovery opened the door to the creation of solid-state neuromorphic hardware that occupies a fraction of the space required by current chips while offering superior performance in specialized tasks. Transitioning from fluid dynamics to nanomagnetics allowed for the conceptualization of low-power processors that could be integrated into everything from medical nanobots to industrial sensors. This scalability ensured that the elegant simplicity of wave-based computing could be translated into rugged components.
Recognizing the commercial and transformative potential of this discovery, Oxford University Innovation moved forward with managing a patent application for the hardware components. This decision signaled a clear transition from laboratory experimentation to industrial application, as researchers assessed the viability of wave-based computing in the broader market. The development process identified that the most effective path toward adoption involved the creation of hybrid systems that utilized wave reservoirs for rapid environmental sensing while maintaining digital processors for high-level logic. Engineers prioritized the design of standardized interfaces that allowed existing robotic platforms to integrate these physical computing modules without requiring a total overhaul of their internal circuitry. This strategy ensured that the massive power savings could be realized in current industrial drones and subsea exploration vehicles. Ultimately, the successful validation of these autonomous units in complex field tests proved that the future of robotics relied on harnessing the intrinsic properties of matter.